|
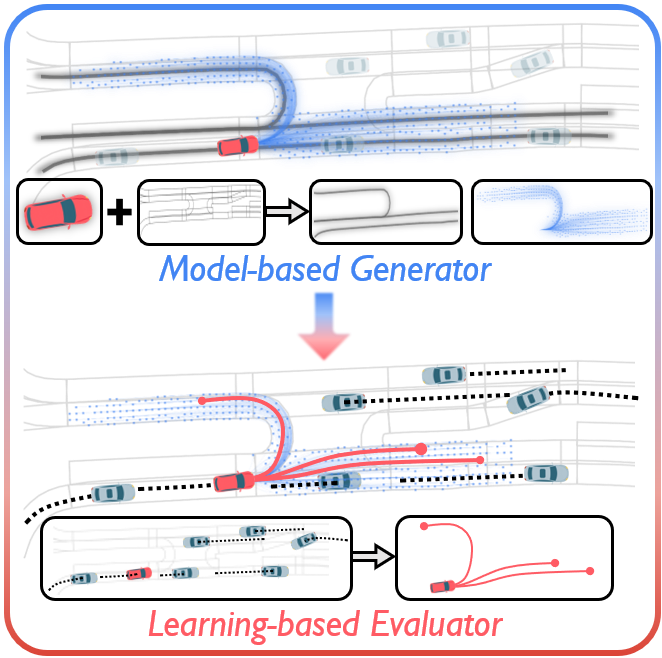
Learning to Predict Vehicle Trajectories with Model-based Planning
Haoran Song, Di Luan, Wenchao Ding, Michael Yu Wang, Qifeng Chen
Conference on Robot Learning (CoRL 2021), London, UK
Ranked 1st on the Argoverse Motion Forecasting Leaderboard as of March 2021
Combining model-based trajectory generation with learned prediction for feasible, robust vehicle trajectories.
project page /
paper /
bibtex
|
|
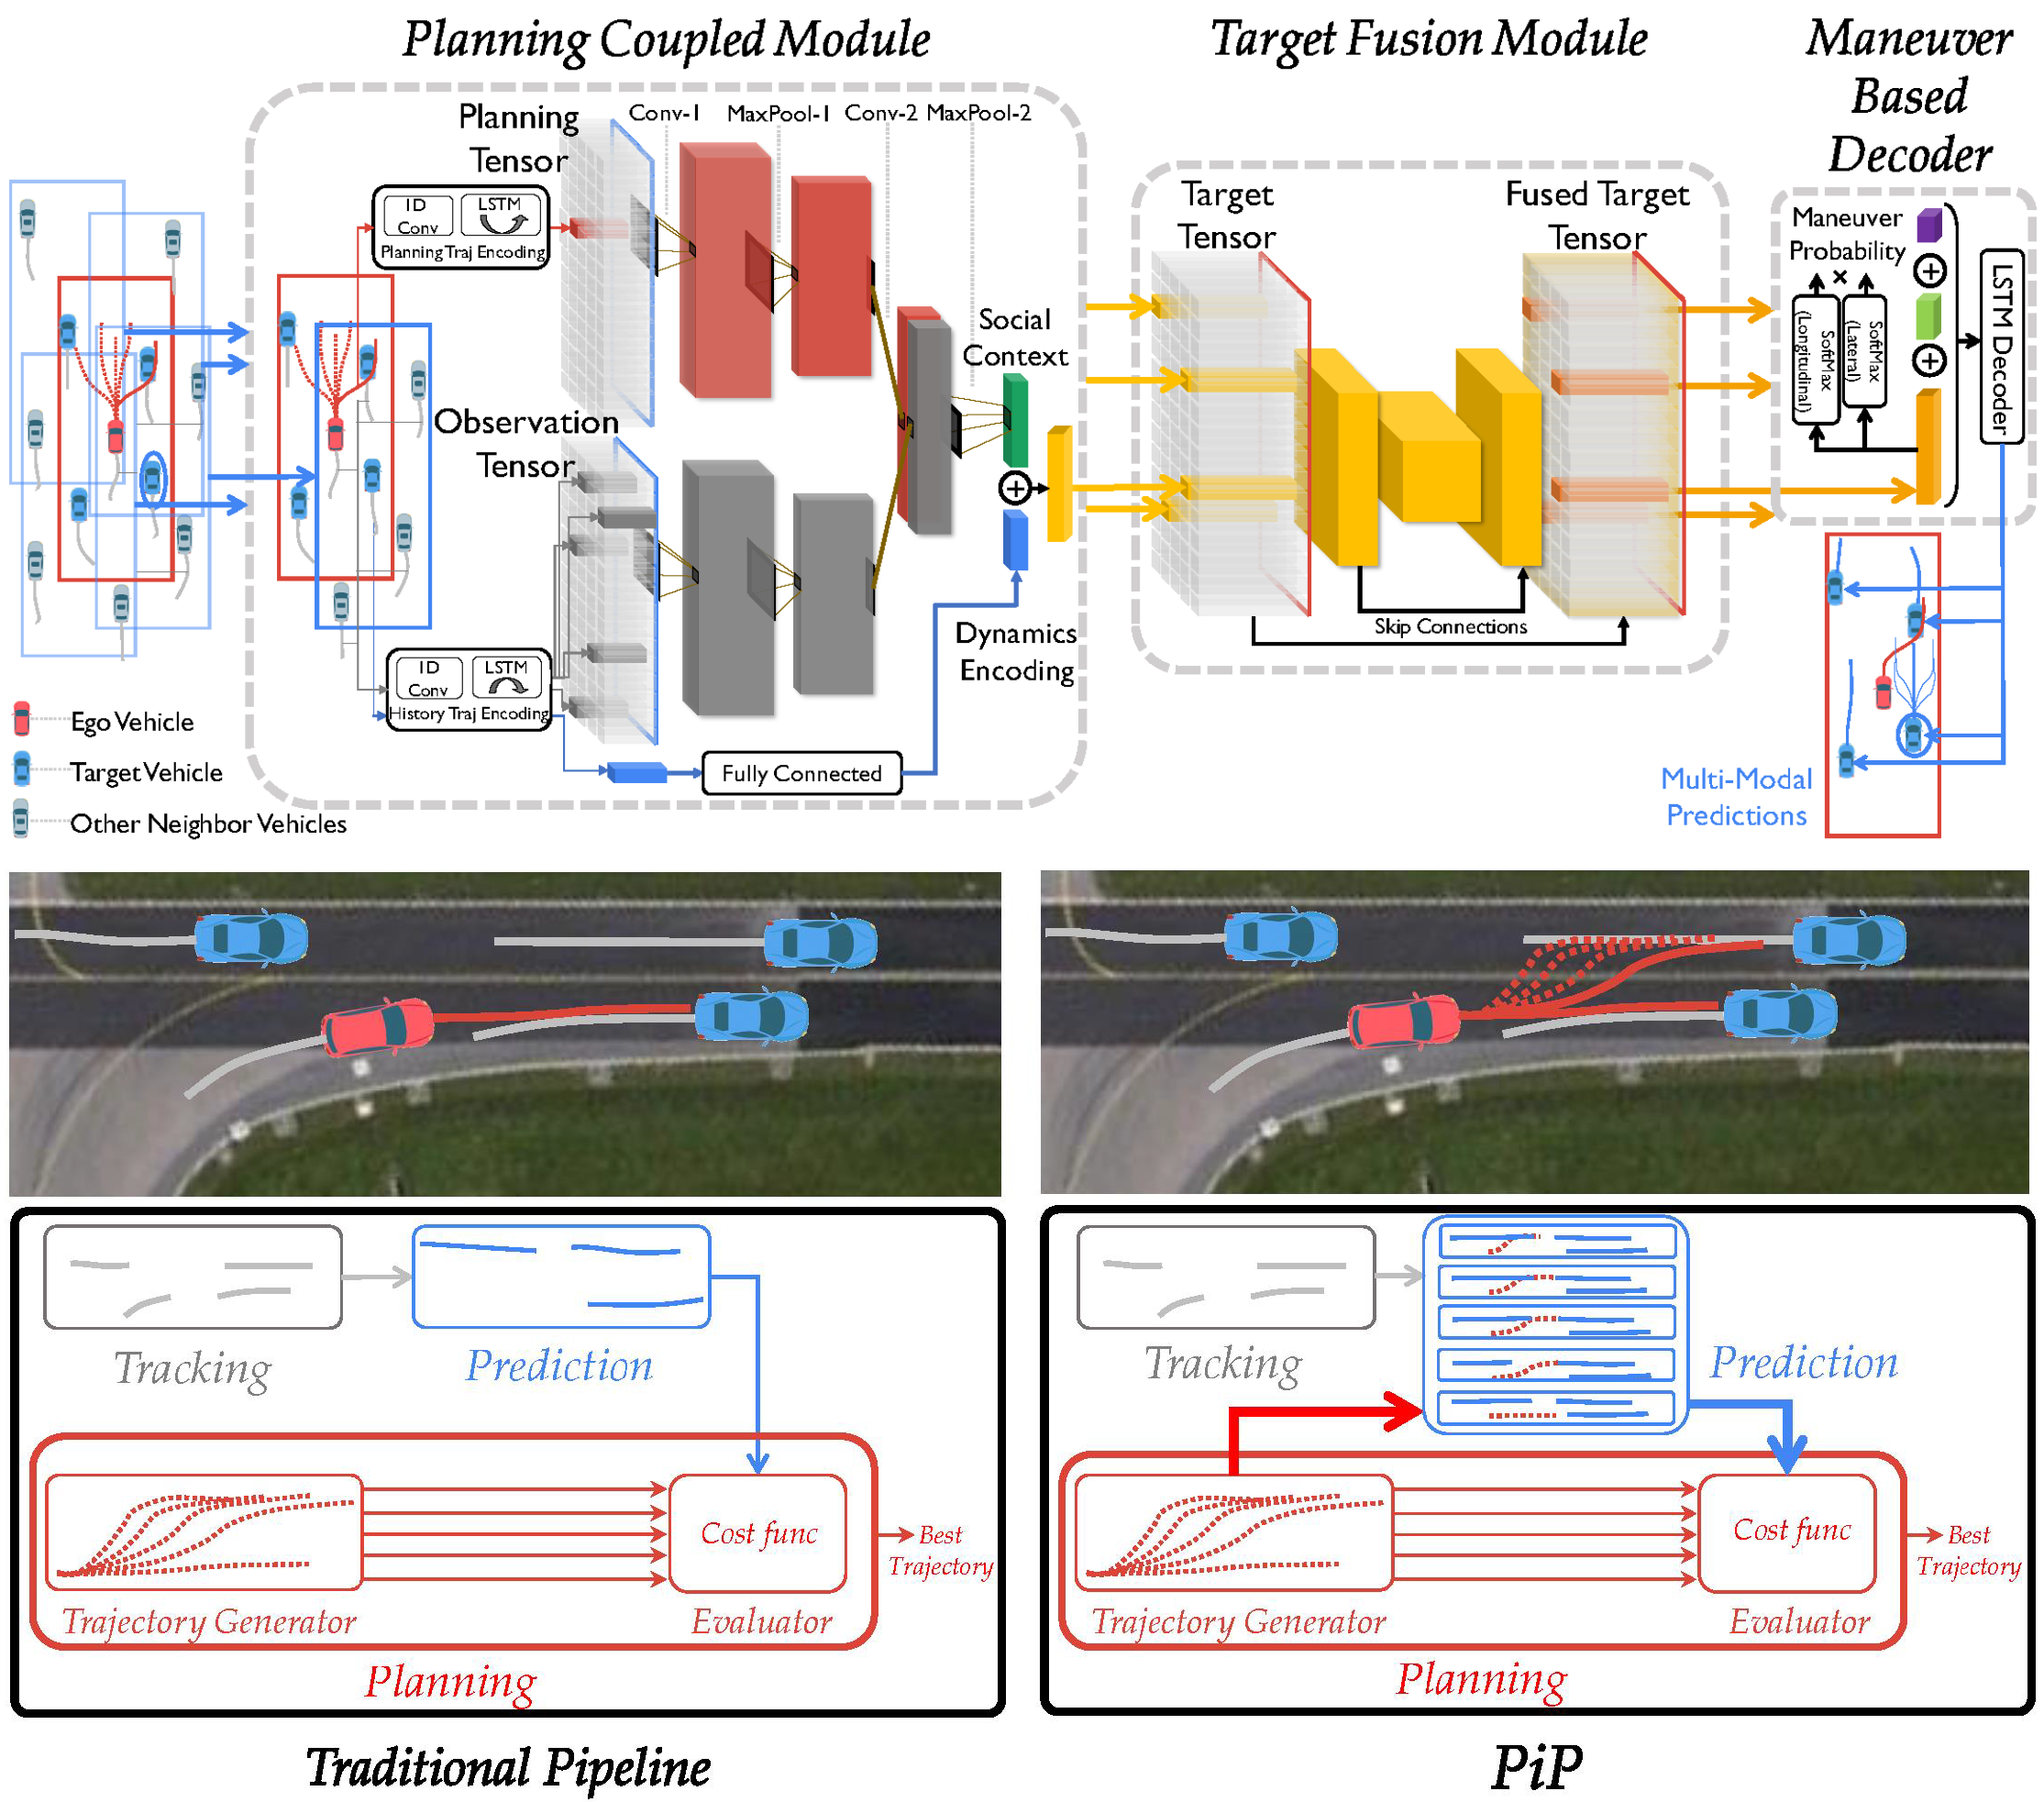
PiP: Planning-informed Trajectory Prediction for Autonomous Driving
Haoran Song, Wenchao Ding, Yuxuan Chen, Shaojie Shen, Michael Yu Wang, Qifeng Chen
European Conference on Computer Vision (ECCV 2020), Glasgow, Scotland, UK
Using ego-vehicle plans to predict how surrounding agents will respond.
project page /
paper /
bibtex
|
|
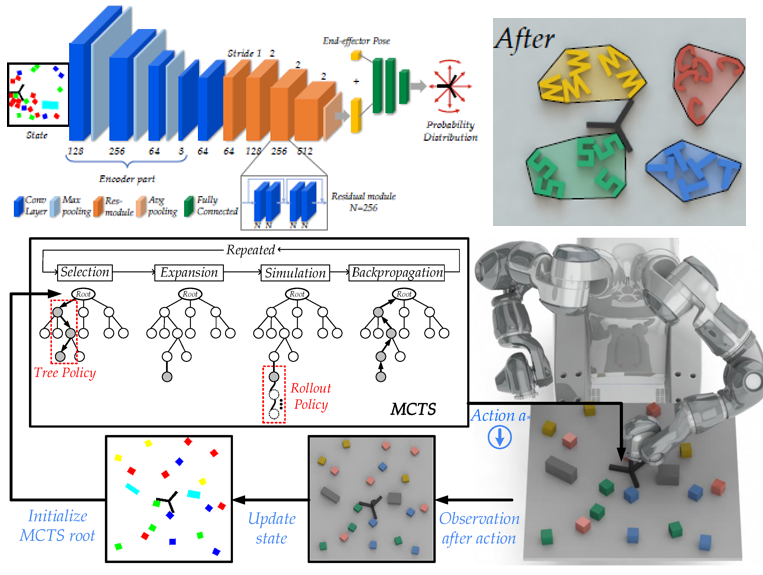
Multi-Object Rearrangement with Monte Carlo Tree Search: A Case Study on Planar Nonprehensile Sorting
Haoran Song*, Joshua A. Haustein*, Weihao Yuan, Kaiyu Hang, Michael Yu Wang, Danica Kragic, Johannes A. Stork
IEEE International Conference on Intelligent Robots and Systems (IROS 2020), Las Vegas, USA
Learning a policy from MCTS-generated data, then feeding it back into MCTS to improve multi-object sorting.
project page /
paper /
bibtex
|
|
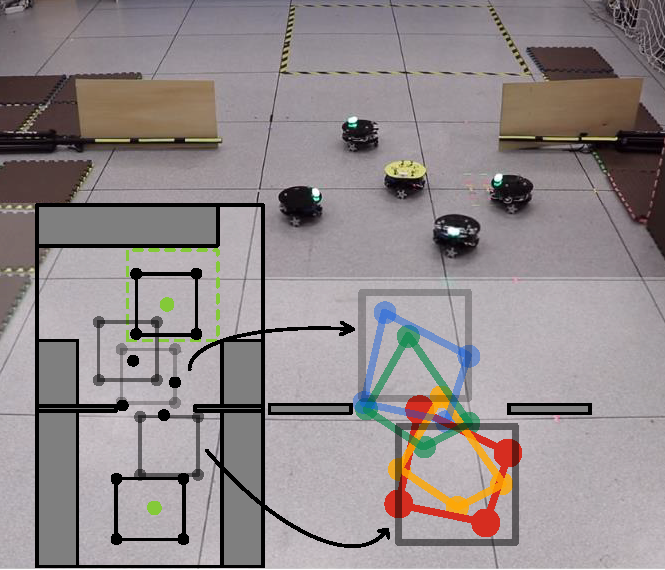
Herding by Caging: A Formation-based Motion Planning Framework for Guiding Mobile Agents
Haoran Song*, Anastasiia Varava*, Oleksandr Kravchenko, Danica Kragic, Michael Yu Wang, Florian T. Pokorny, Kaiyu Hang
Autonomous Robots (AURO), 2021
Using geometry and topology to plan robot formations that guide mobile agents.
paper /
video
|
|
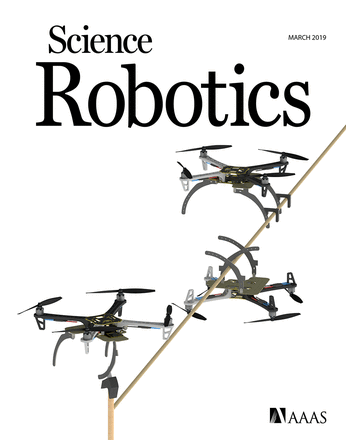
Perching and resting - A paradigm for UAV maneuvering with modularized landing gears
Kaiyu Hang*, Ximin Lyu*, Haoran Song*, Johannes A Stork*, Aaron M Dollar, Danica Kragic, Fu Zhang
Science Robotics, 2019
Cover article
Enabling UAVs to perch and rest on structures, saving energy while maintaining stable viewpoints.
Featured in
MIT Technology Review,
Nature Electronics,
National Public Radio, etc.
paper /
video /
bibtex
|
|
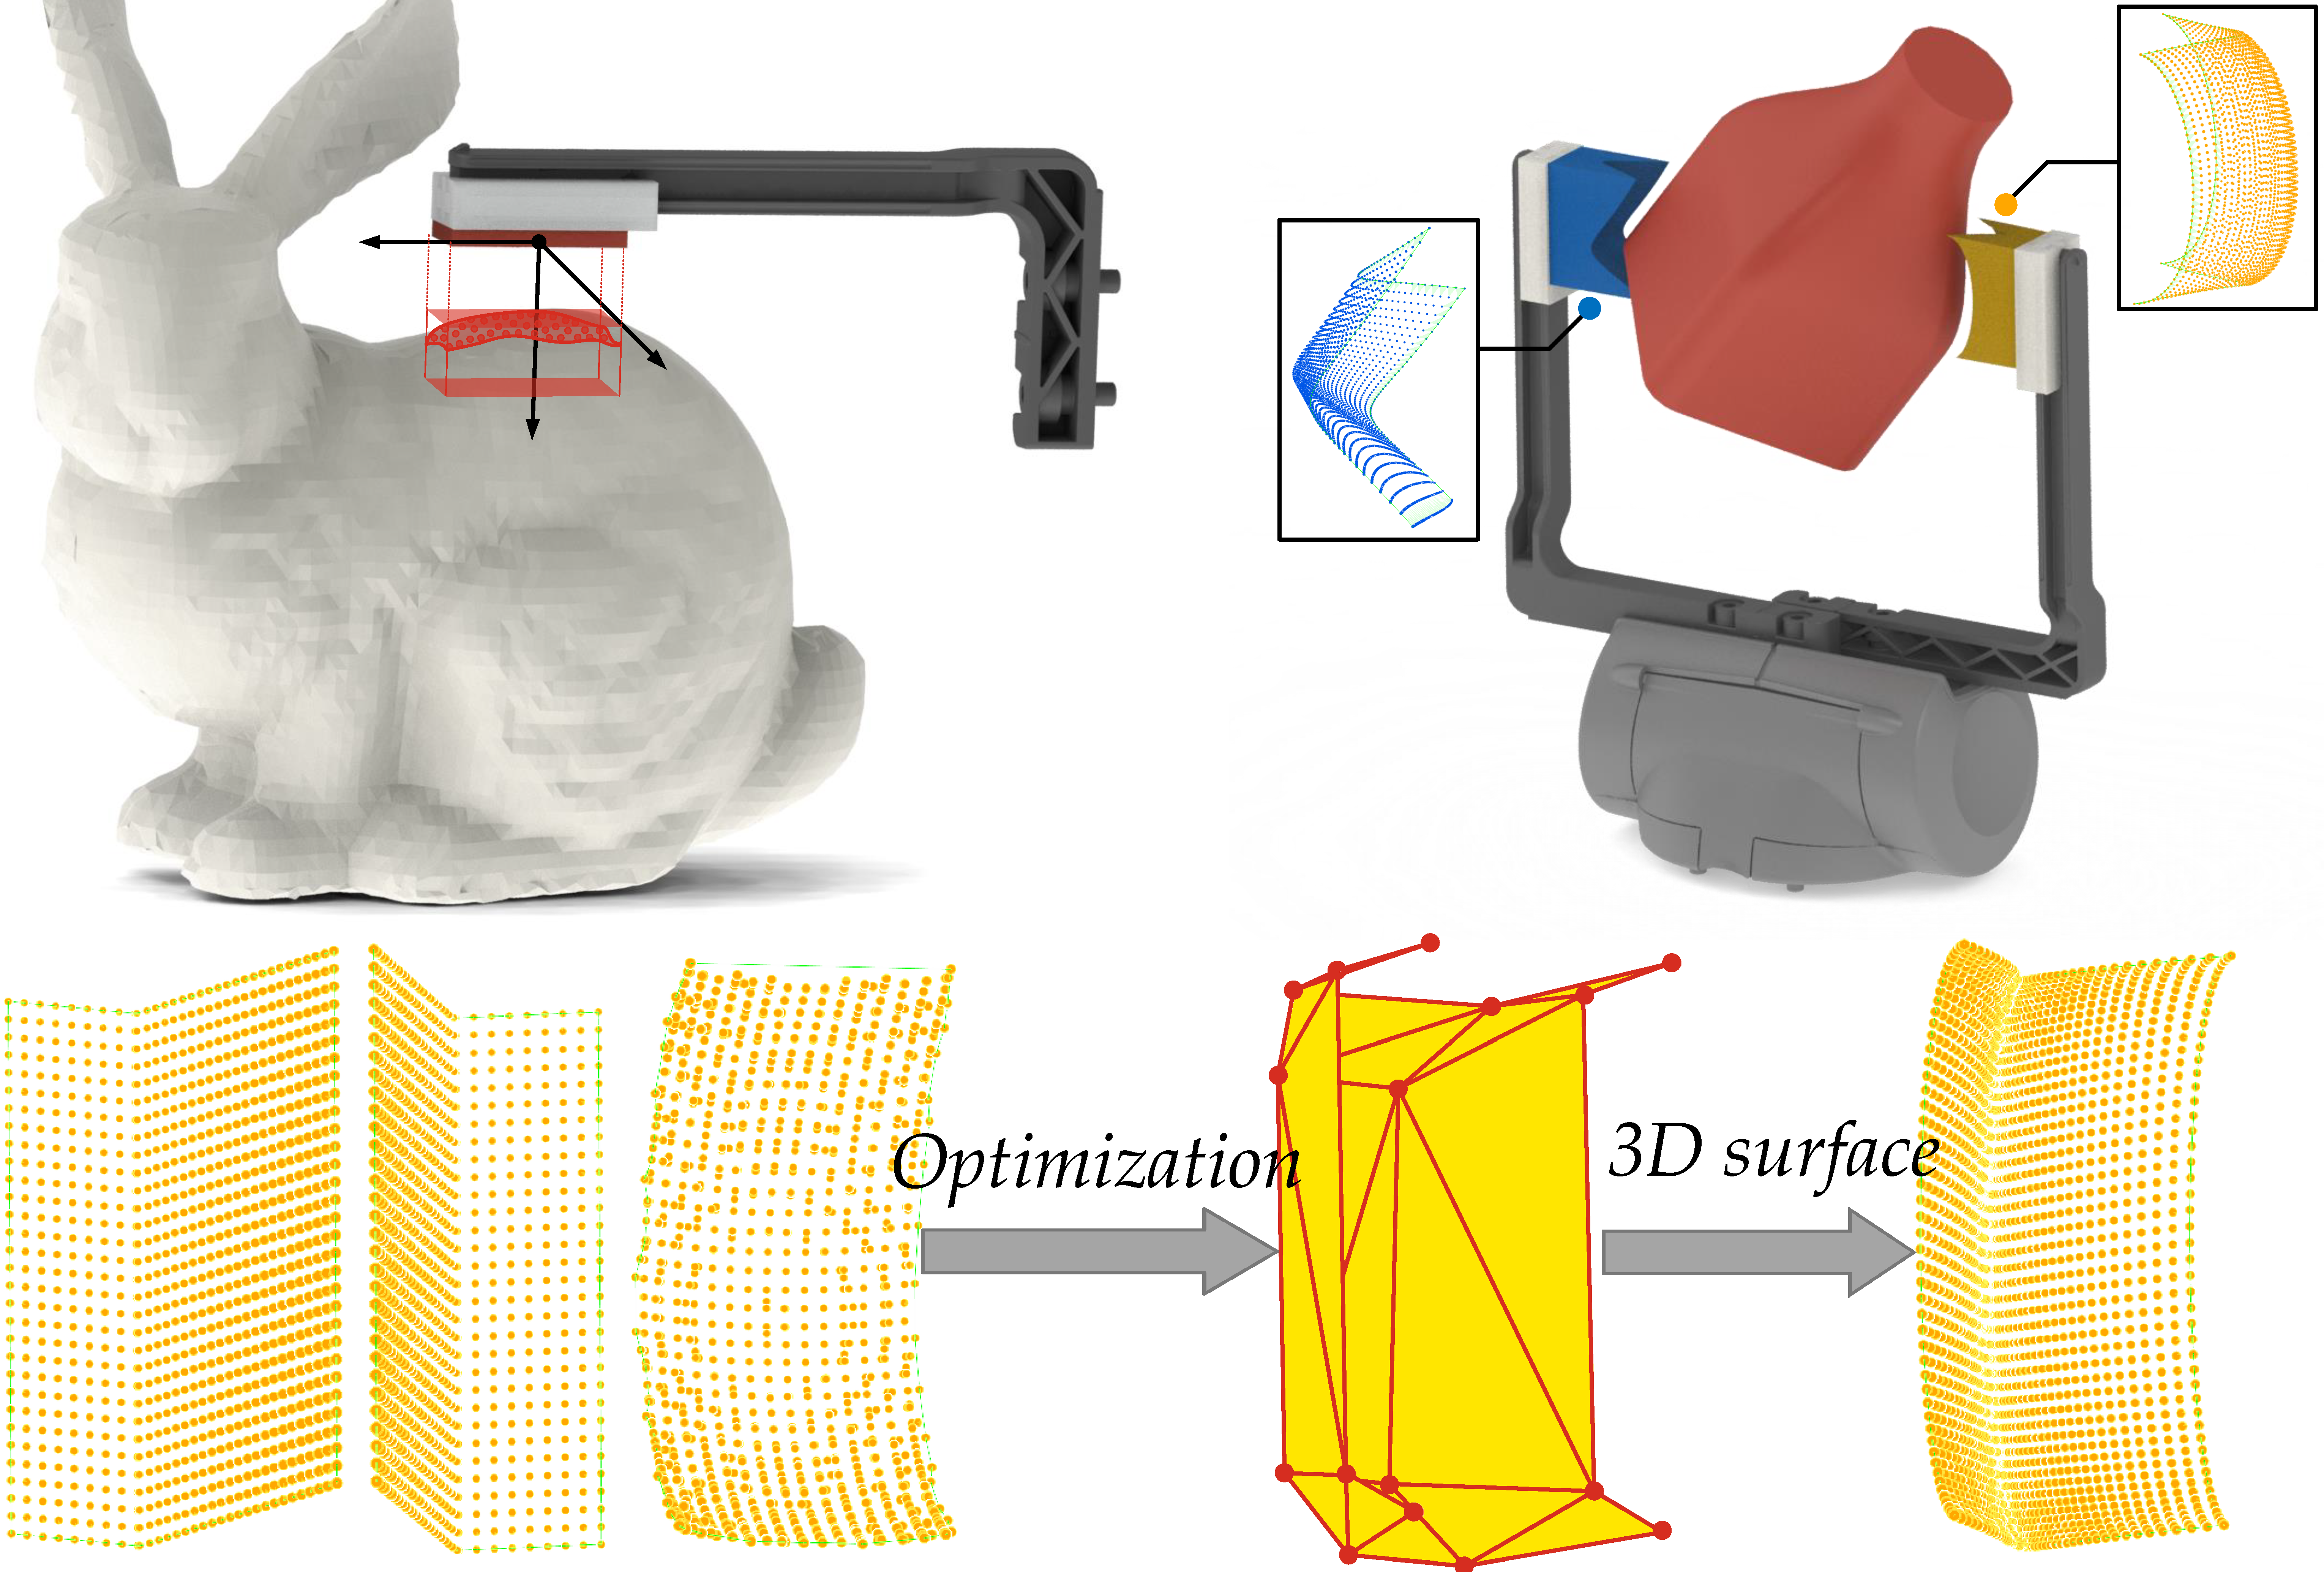
Fingertip surface optimization for robust grasping on contact primitives
Haoran Song, Michael Yu Wang, Kaiyu Hang
IEEE Robotics and Automation Letters (RA-L), 2018 &
IEEE International Conference on Robotics and Automation (ICRA 2018), Brisbane, Australia
Reframing robust grasp planning as geometric matching with learned contact geometries.
paper /
bibtex
|